Robot training datasets
Robot foundation models are bottlenecked by diverse, real-world manipulation data. Human egocentric video is the most scalable source: it is cheaper to collect than teleoperation and covers far more environments.
The datasets below are in stock today. If you need robot-side demonstrations with joint states and actions, see teleoperation under custom collection.
Custom collection
Robot Teleoperation Data
Robot-side demonstrations — joint states, actions and wrist/head camera video — collected on your hardware or ours to your task spec.
- Bimanual arm demonstrations
- Humanoid whole-body teleop
- Handheld gripper (UMI-style) capture
Custom collection
New Environments & Scenarios
Healthcare support, agriculture, automotive, outdoor work and other settings not yet in stock, recorded to your scenario list.
- Healthcare support tasks
- Agricultural harvesting
- Automotive service
Datasets
Search all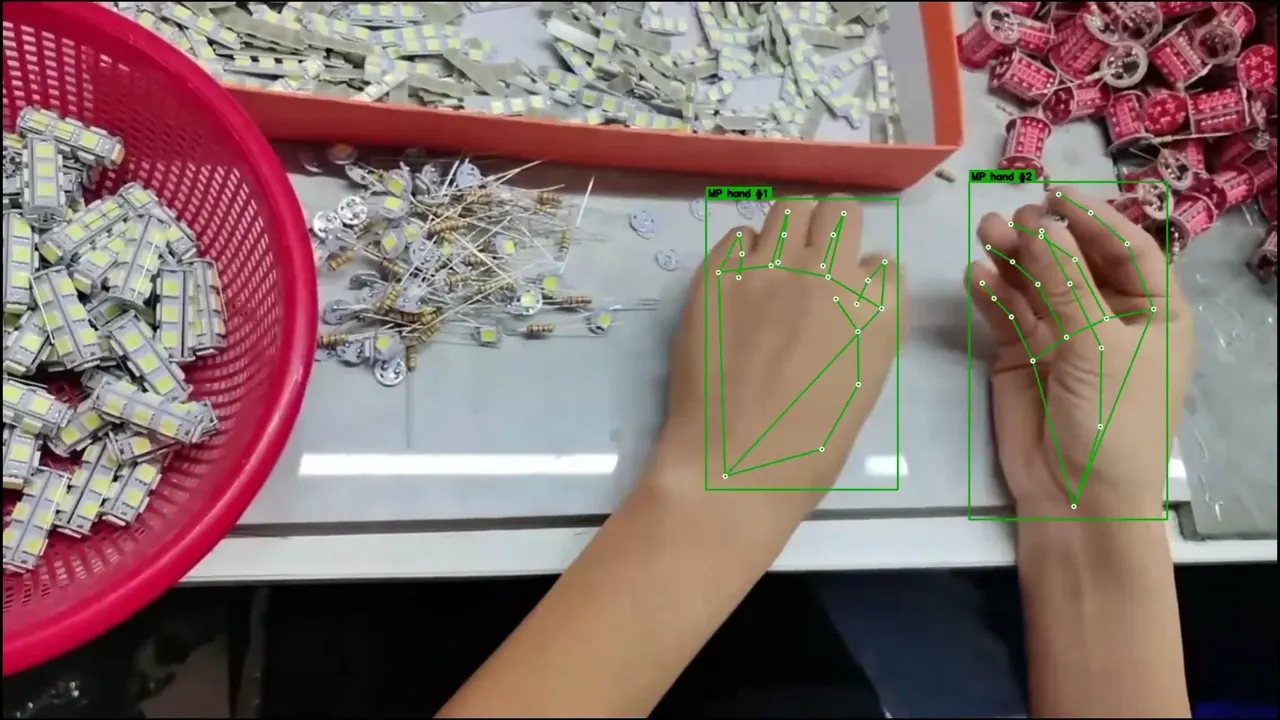
In stock176,000 h
PreviewManufacturing & Production
Request Quote $35/h · 2 scenarios
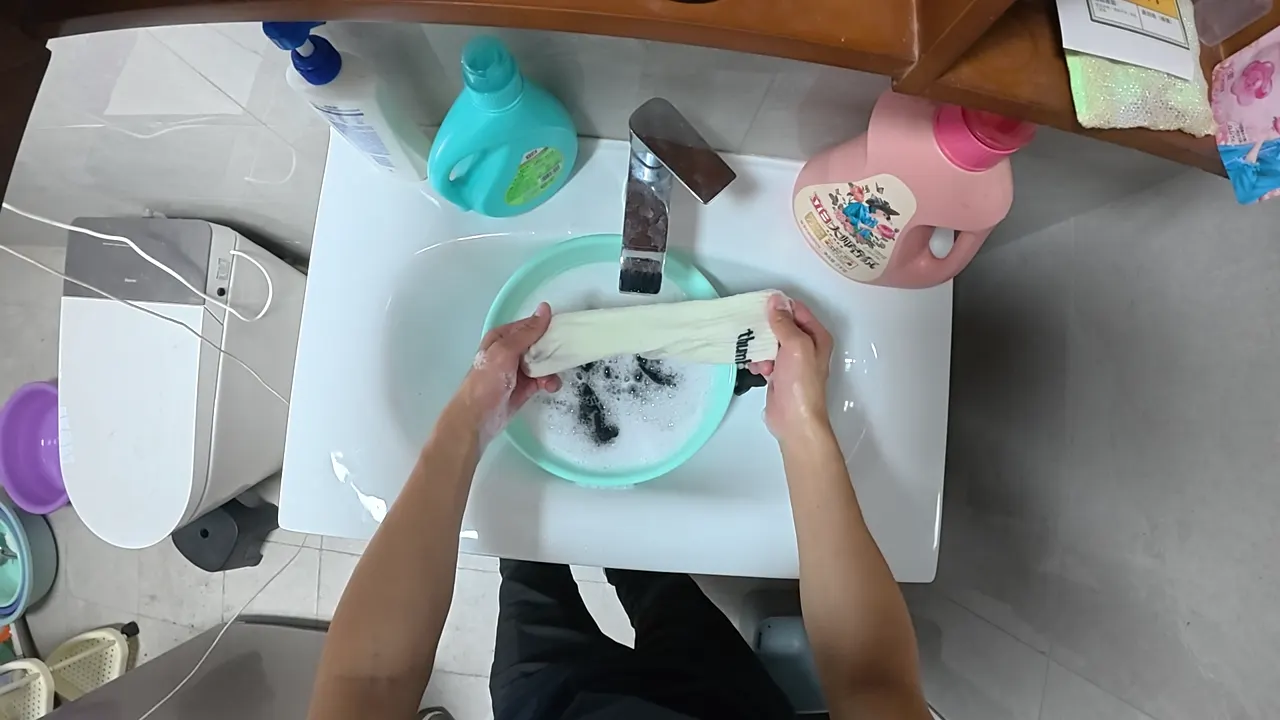
In stock152,000 h
PreviewHousehold Services
Request Quote $35/h · 3 scenarios
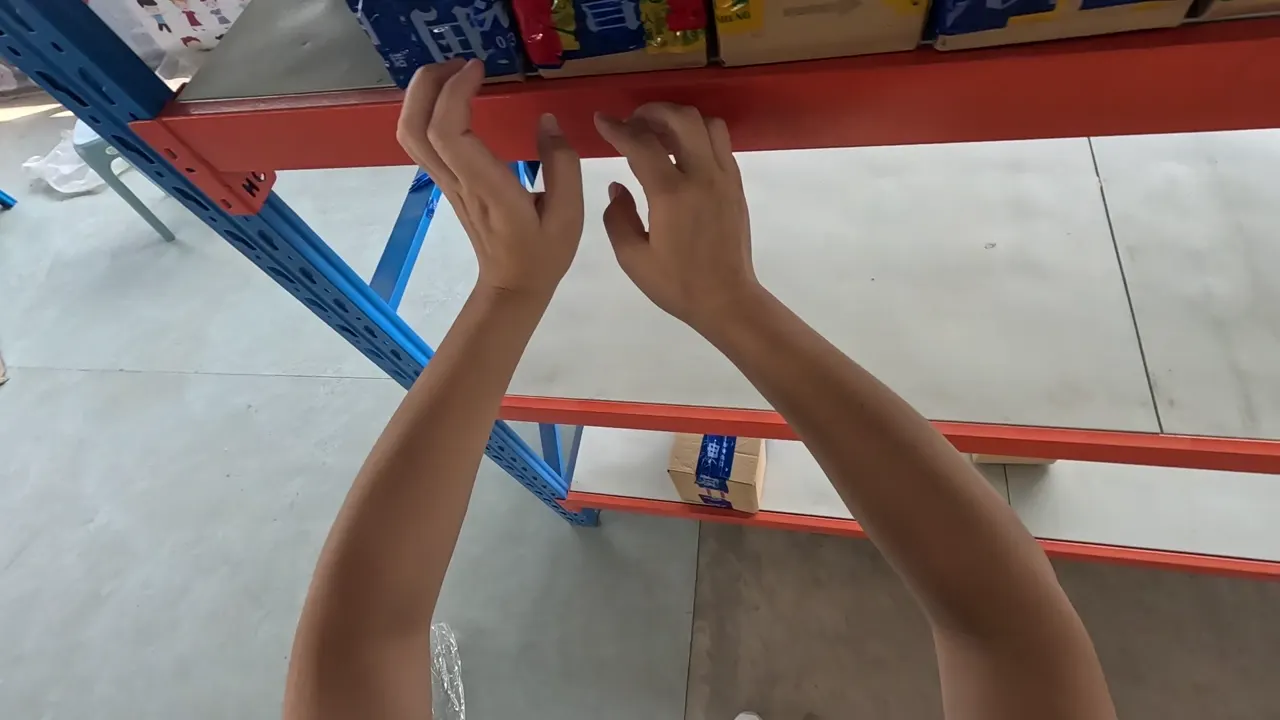
In stock136,000 h
PreviewWarehousing & Logistics
Request Quote $25/h · 3 scenarios
In stock120,000 h
Retail ServicesIllustration · sample video pending
Retail Services
Request Quote $25–35/h
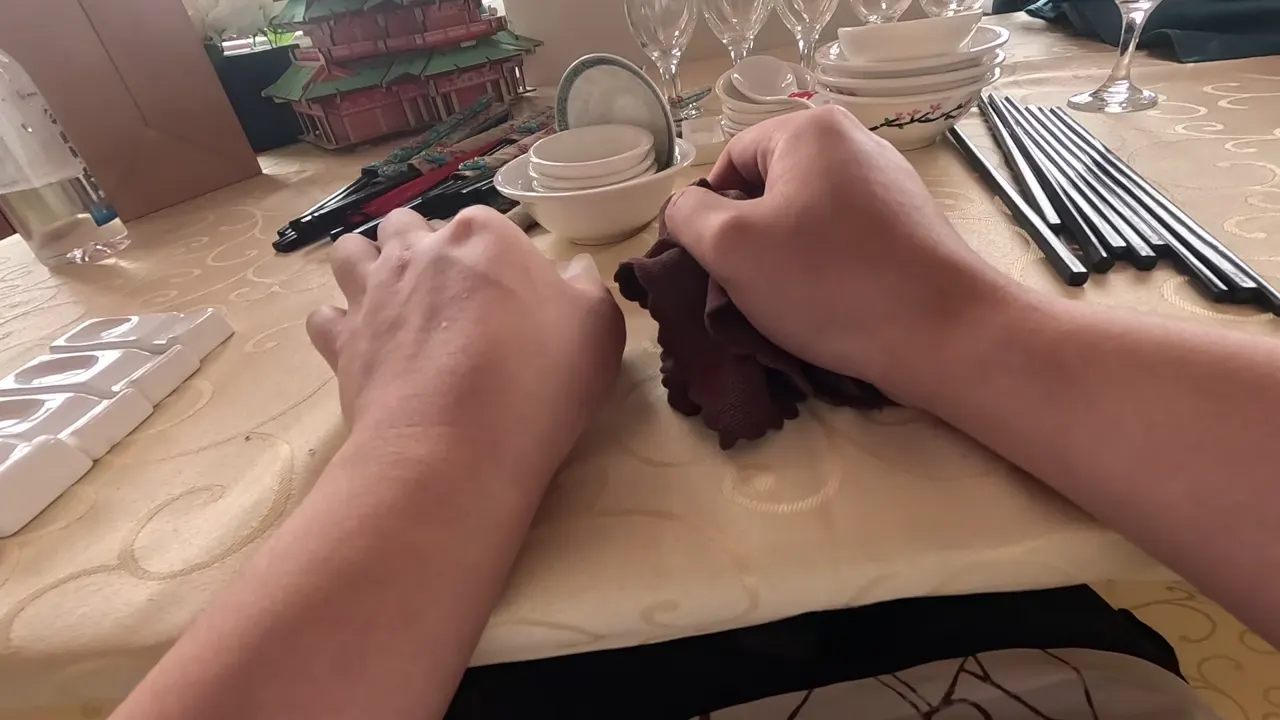
In stock104,000 h
PreviewFood Service & Hospitality
Request Quote $25/h · 2 scenarios
In stock72,000 h
PreviewSpecialized Operations
Request Quote $25–35/h · 6 scenarios
In stock40,000 h
Hospitality & AccommodationIllustration · sample video pending
Hospitality & Accommodation
Request Quote $25–35/h